Imaging Excellence Meets Autonomy
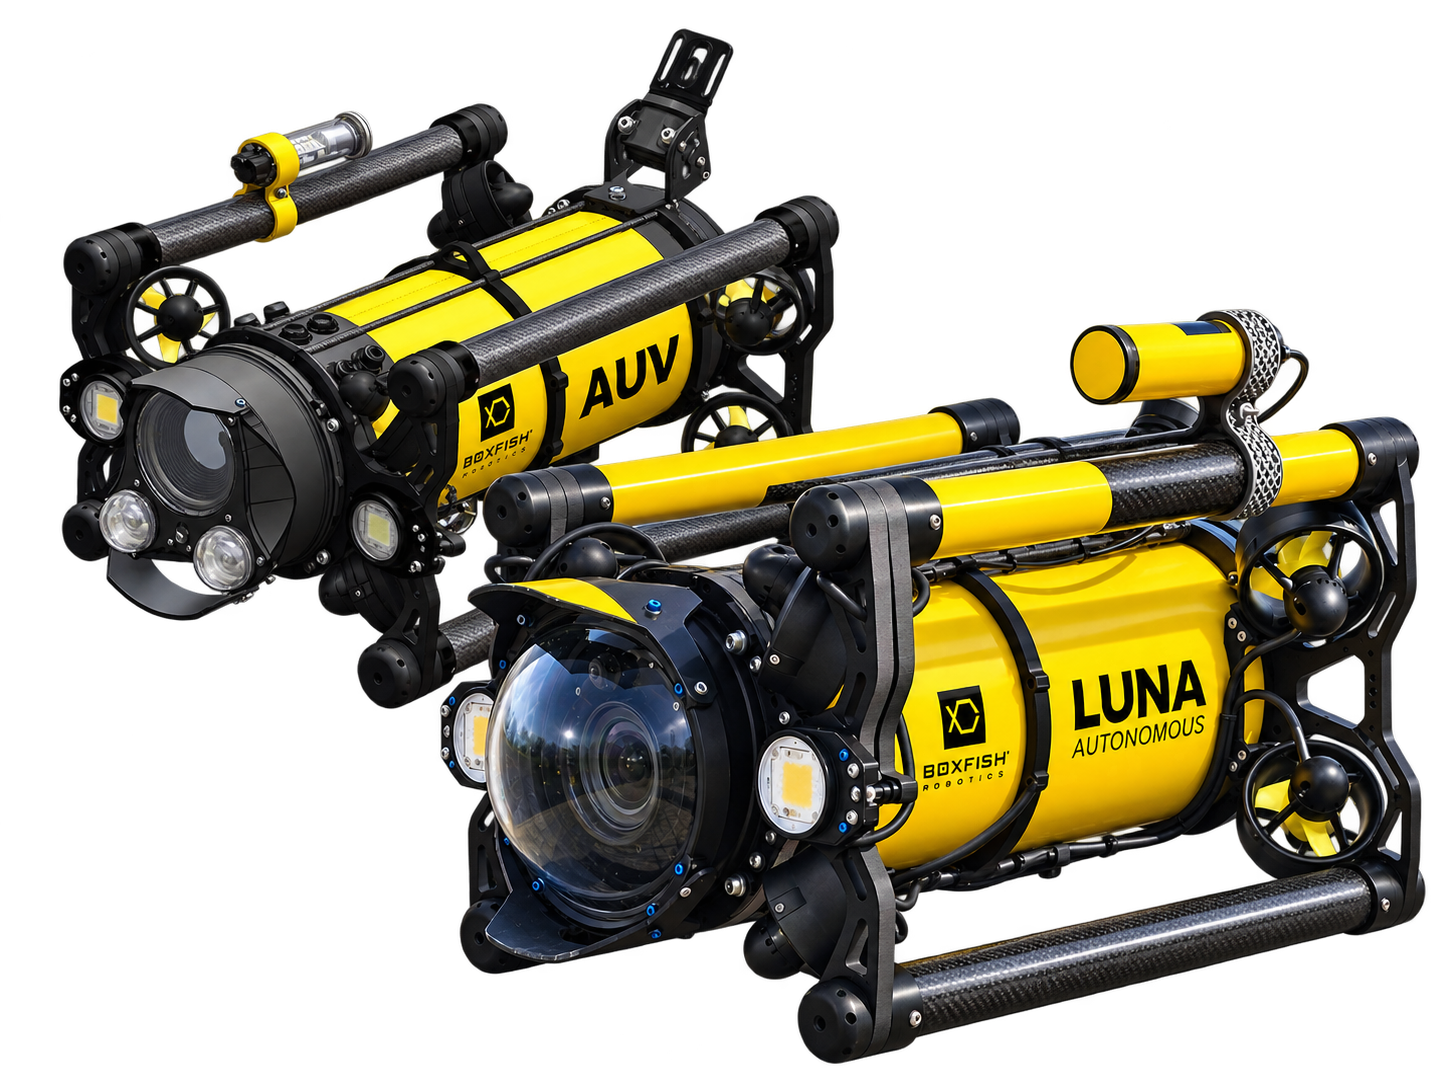
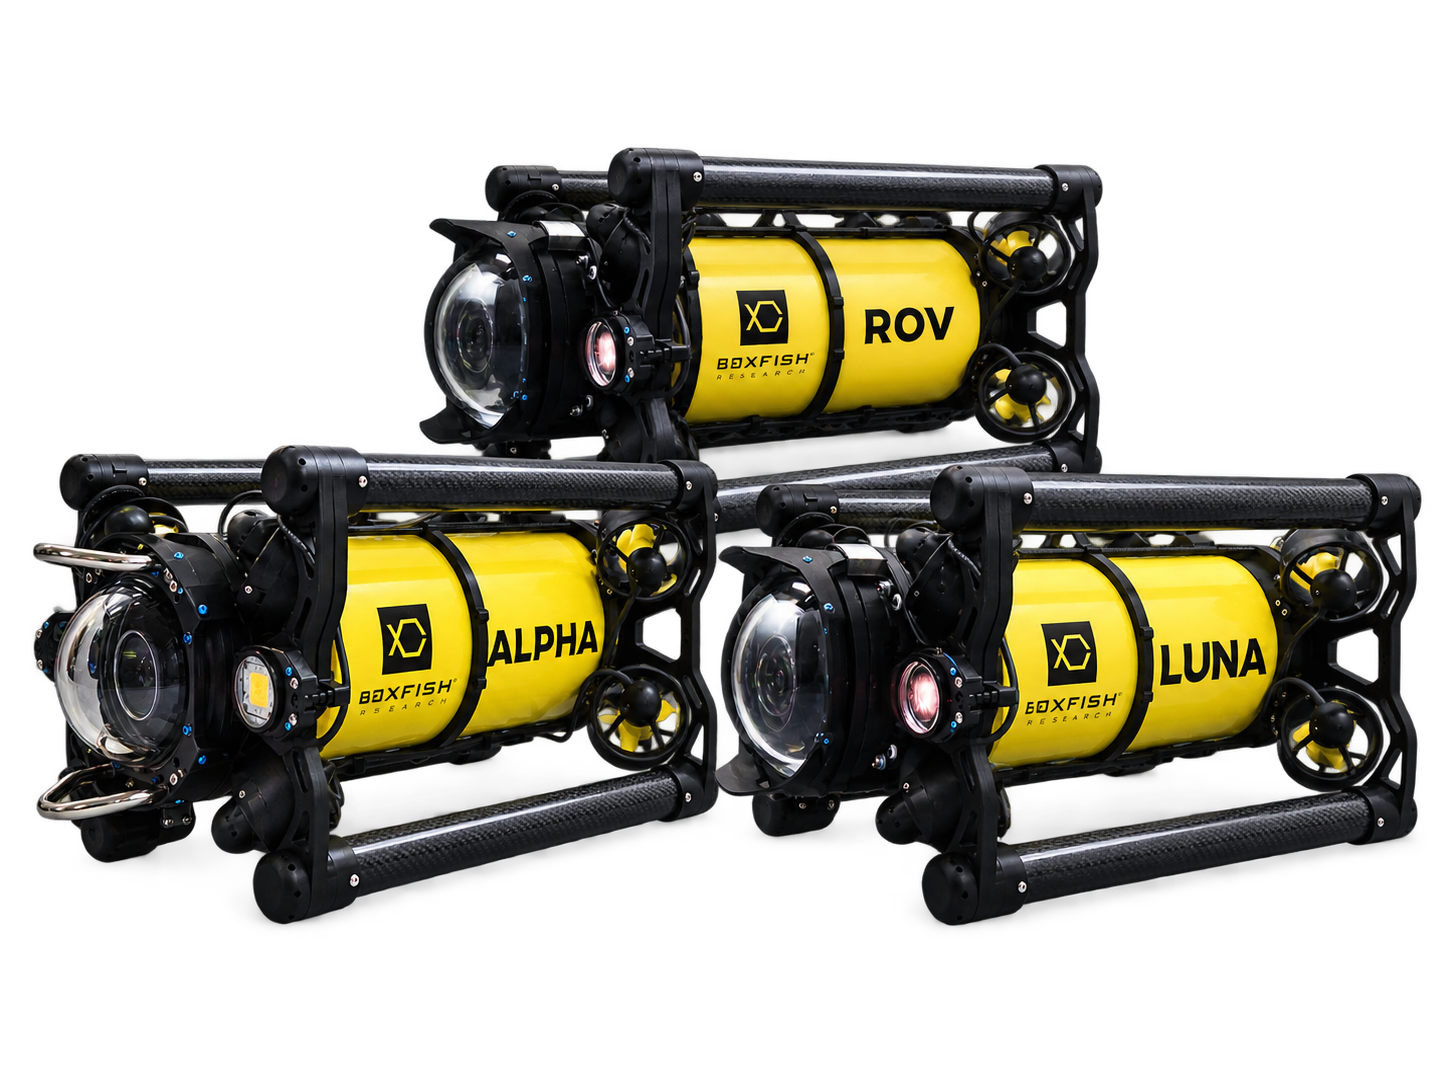
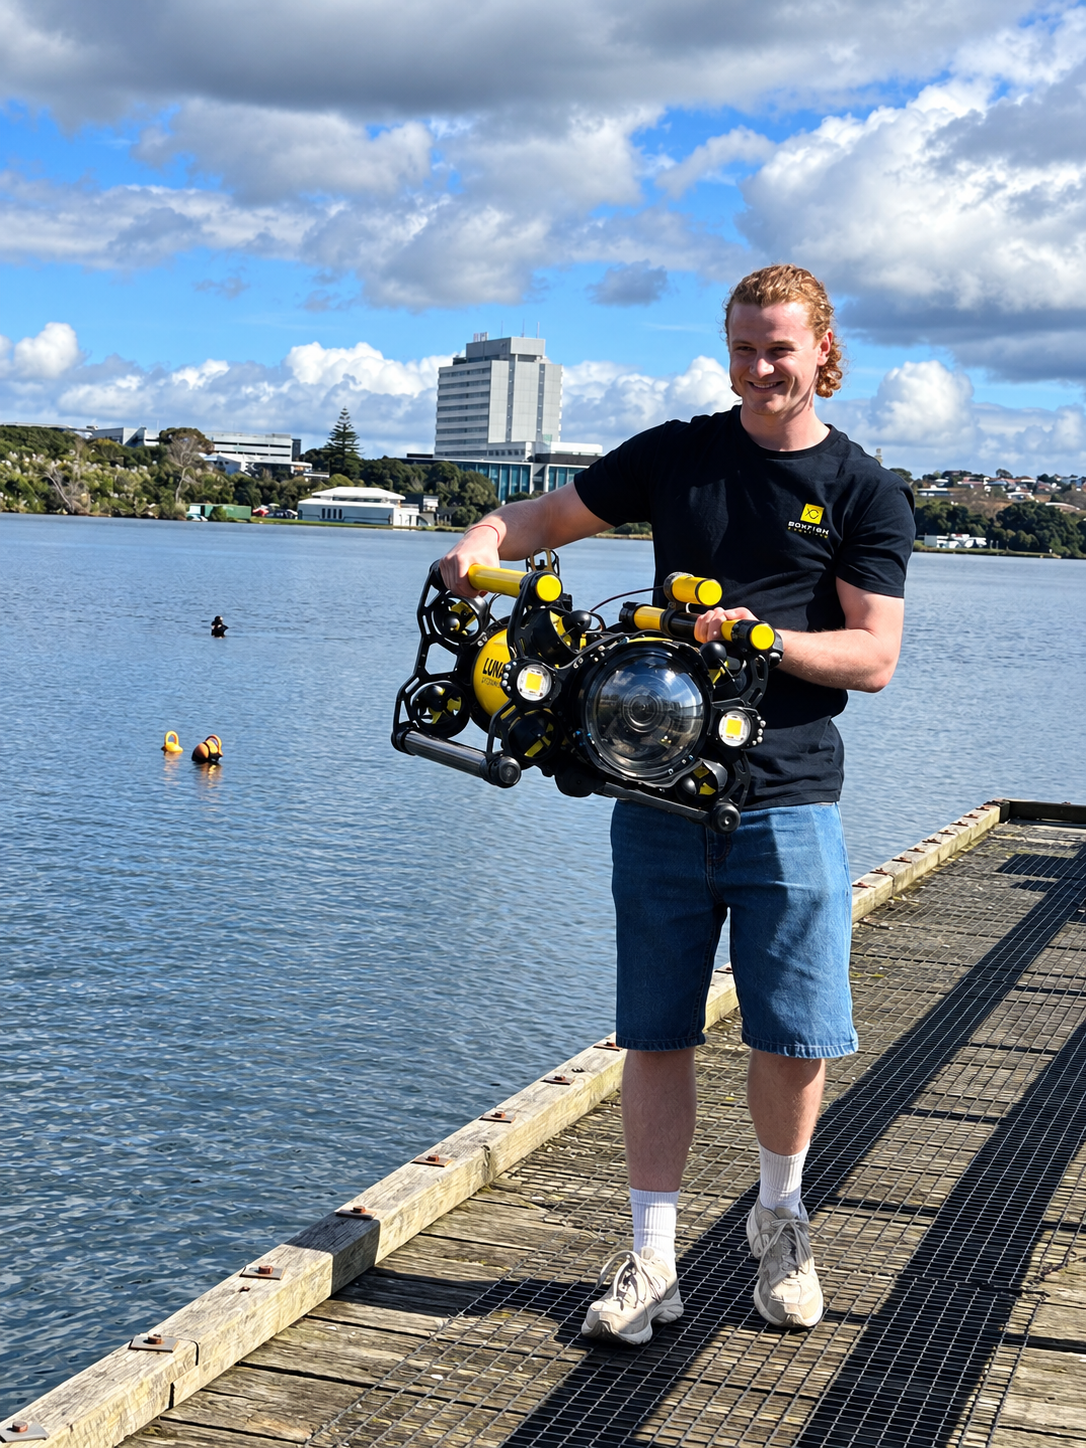
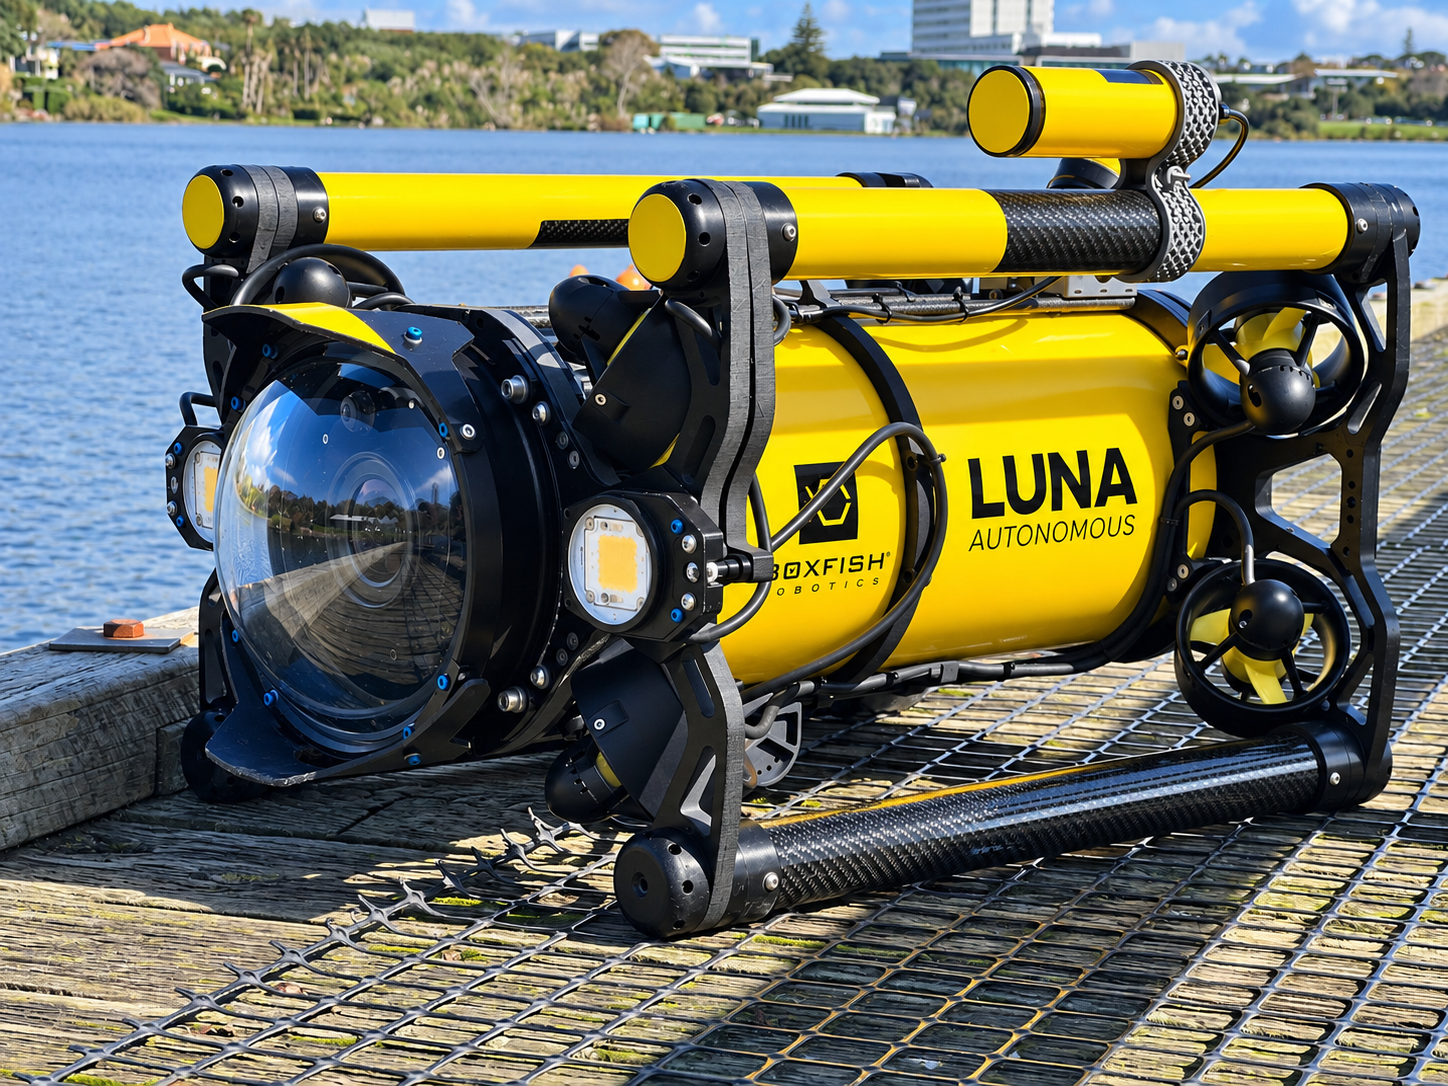
Built on Boxfish Robotics’ proven patented hovering vehicle architecture, Luna AUV combines full-frame imaging, precise navigation and autonomous operation in a compact platform designed for visual surveys, photogrammetry and environmental monitoring.
Full-frame imaging
Built around a full-frame imaging system, Luna AUV captures high-resolution 50 MP RAW imagery and 4K video up to 60 fps. The system is optimised for photogrammetry, habitat mapping and visual survey applications where image quality and detail are critical.
Autonomous or tethered
Luna AUV can operate fully autonomously for repeatable survey missions or tethered for real-time observation and inspection. This flexibility allows users to move seamlessly between data collection and direct operator control.
Repeatable surveys
Precise navigation and low-altitude operation enable consistent visual surveys over time. Return to the same location with confidence to support environmental monitoring, change detection and repeatable photogrammetric surveys.
Coral reef monitoring
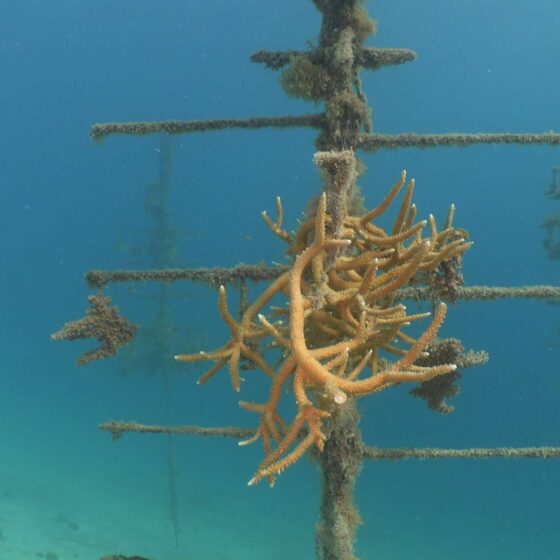
Monitor reef health, bleaching events and ecosystem recovery across complex reef structures, walls and varied underwater terrain. Six-degree-of-freedom hovering control allows Luna AUV to capture imagery from multiple perspectives while maintaining precise low-altitude positioning for repeatable monitoring and change detection.
Fish surveys and biodiversity studies
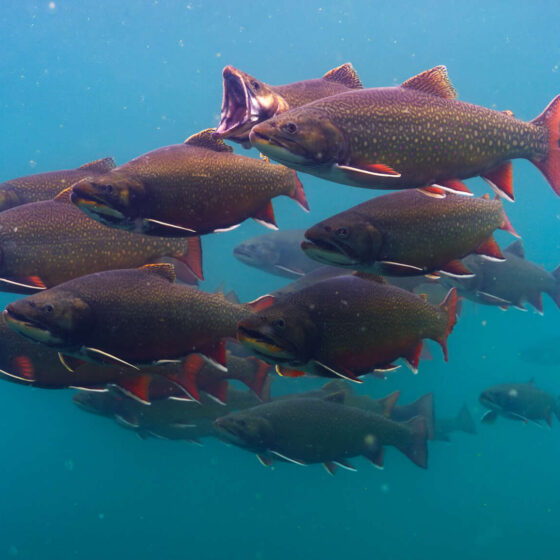
Conduct visual fish surveys around reefs and complex habitats. Stable hovering and precise manoeuvring support detailed observations while optional stereo camera payloads can assist with abundance studies, species identification and fish sizing.
Photogrammetry & SfM
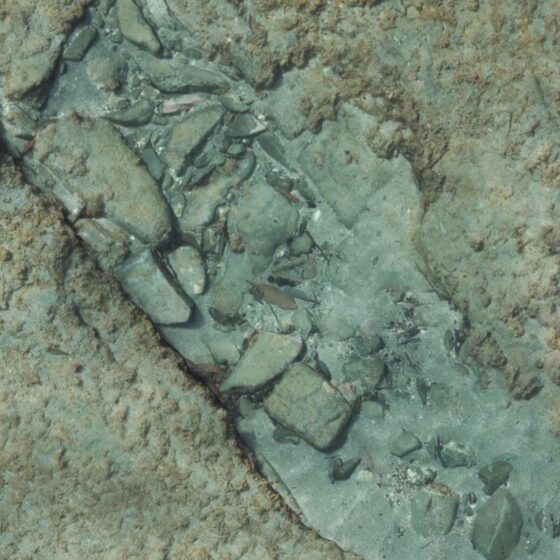
Create detailed geo-referenced 3D models of reefs, habitats and underwater structures. Full-frame imaging and low-altitude operation support photogrammetric models with sub-millimetre resolution, enabling accurate mapping, measurement and quantitative analysis of complex underwater environments.
Environmental monitoring
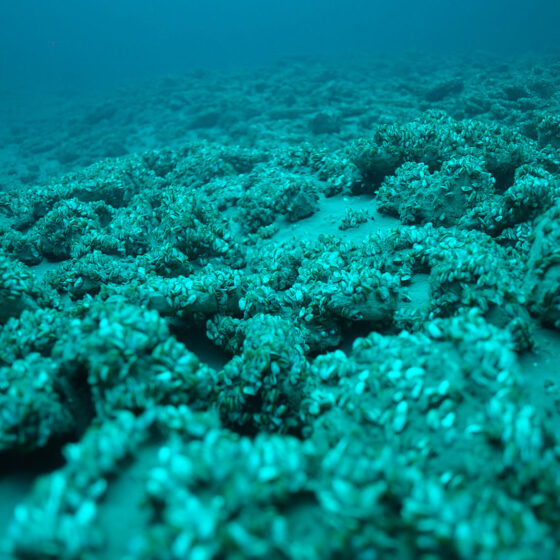
Collect repeatable visual datasets across reefs, seagrass beds, rocky habitats and artificial structures. Sensor-fusion navigation delivers sub-metre positioning accuracy, enabling meaningful comparison between survey periods and supporting long-term environmental monitoring programmes.
Which AUV is right for your mission?
Every Boxfish AUV platform is built on the same proven software, navigation and data collection architecture.
- Geo-referenced imagery and video
- Easy to use mission planning, monitoring and control software
- RAW image capture and 4K video recording
- Hovering vehicle architecture with six degrees of freedom control
- Environmental sensor integration
- Photogrammetry-ready workflows and outputs
The difference lies in how each platform is optimised for specific mission requirements.
| Boxfish LUNA AUV | Boxfish AUV | ARV-i | |
|---|---|---|---|
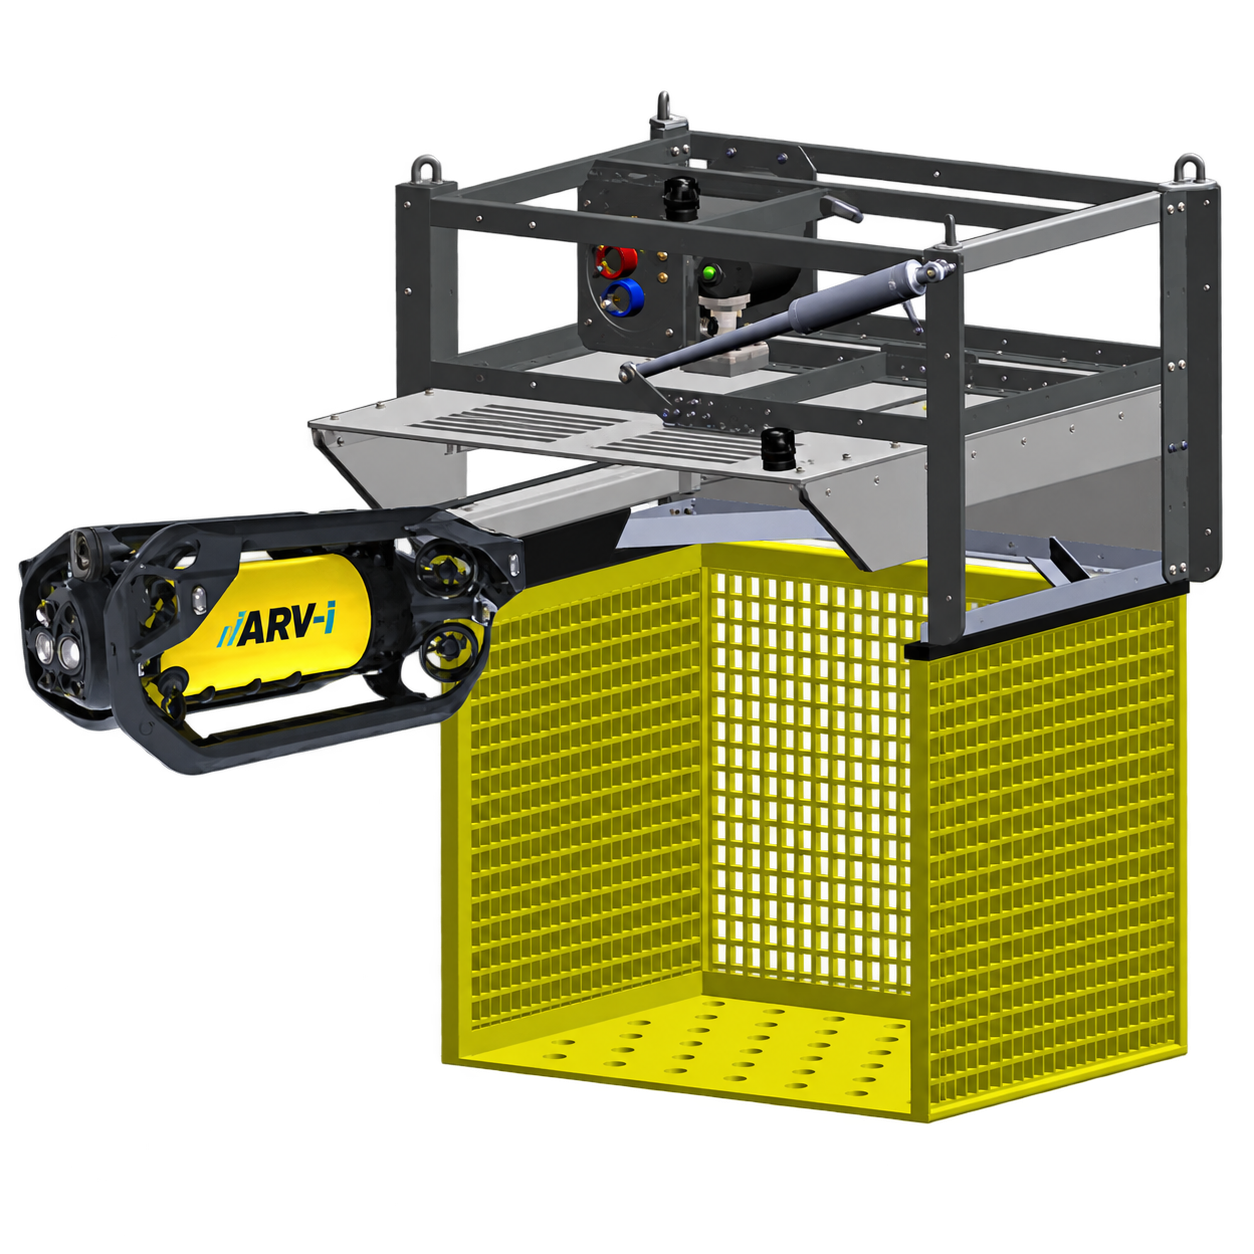
| Primary purpose | Autonomous visual survey and photogrammetry | Autonomous scientific survey and photogrammetry | Underwater resident monitoring and inspection |
| Best fit for | Coral reef monitoring, fish surveys, habitat mapping, photogrammetry, environmental monitoring | Marine science, environmental monitoring, sensor integration and advanced autonomy applications | Long-term monitoring of underwater assets |
| Key Differentiator | Sony full-frame imaging system | Stereo perception | Docking and resident operation |
| Key Benefit | Highest quality visual datasets and repeatable imaging surveys | Greater situational awareness and capability around complex underwater structures | Persistent autonomous monitoring from a subsea dock |
Review full comparison table here
Example Outputs
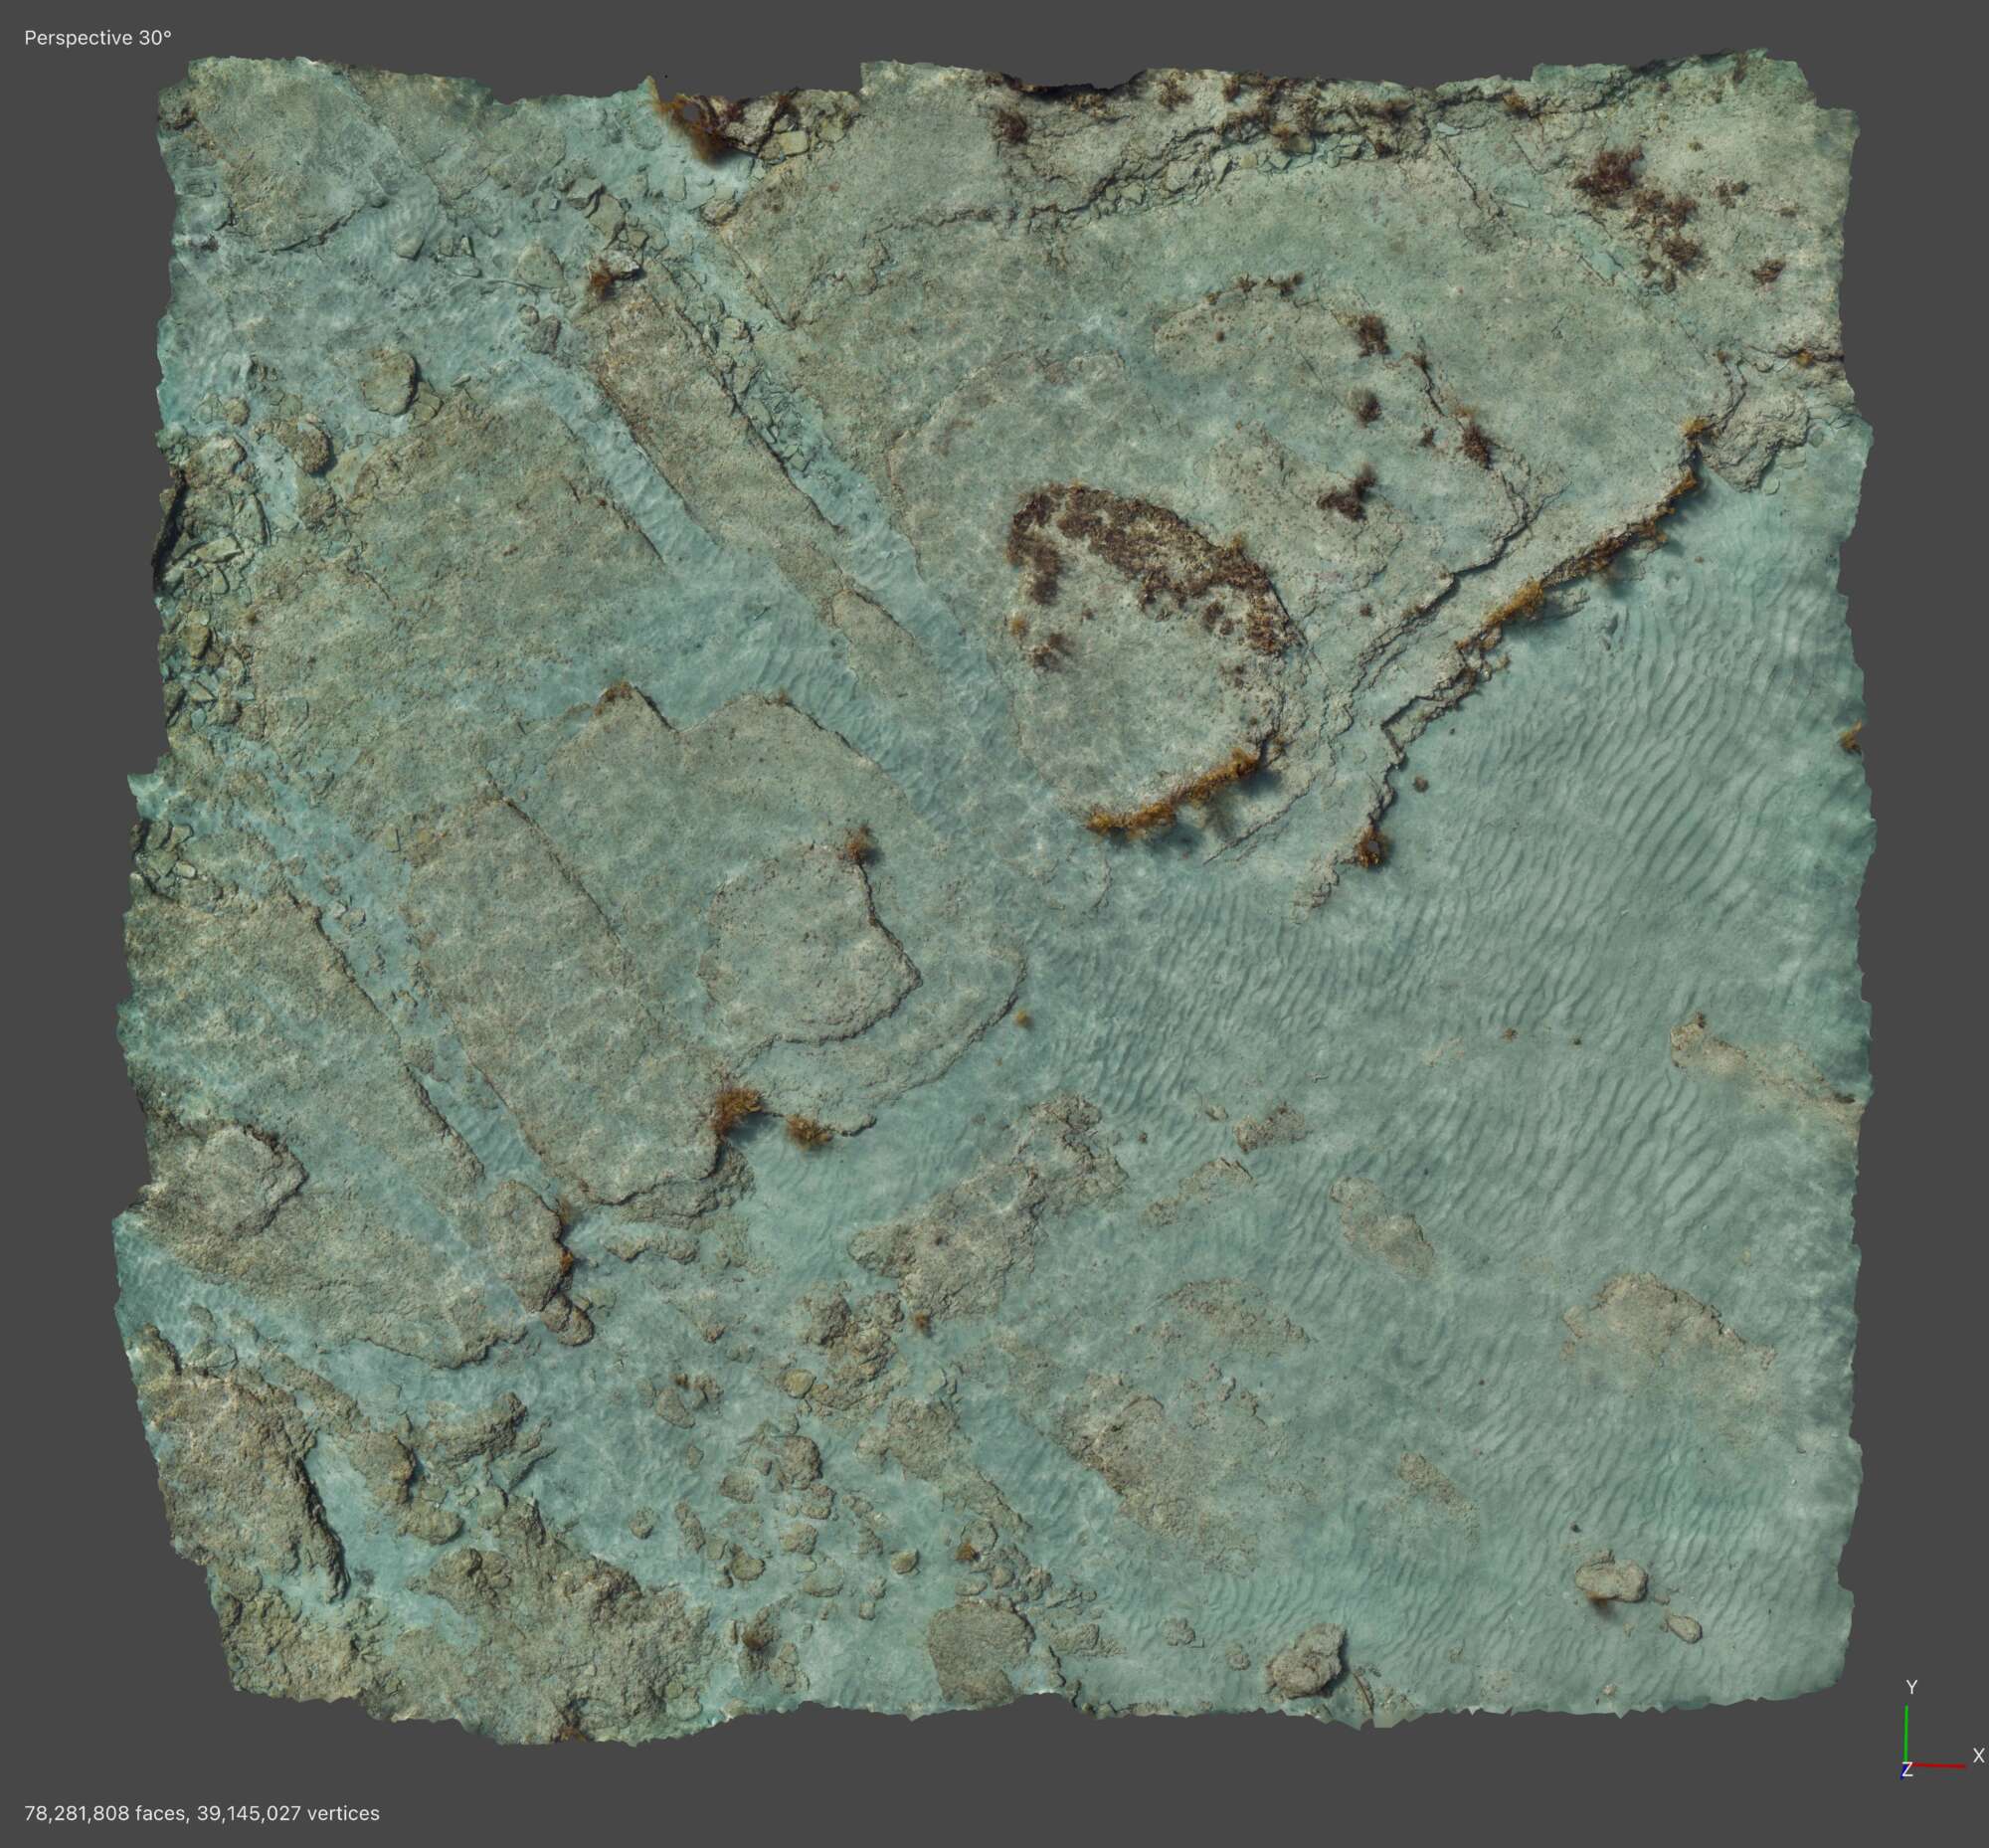
Benthic photogrammetry
This 15 × 15 m photogrammetric model was created from a tidal survey conducted at Goat Island, New Zealand. Imagery was collected at 0.8 m altitude and 0.3 m/s using Luna AUV and processed in Agisoft Metashape.
High-resolution imaging, low-altitude surveys and precise navigation enable detailed habitat mapping, measurement and environmental monitoring.
Contact us to view the full-resolution model and explore the level of detail achievable through sub-millimetre reconstruction.
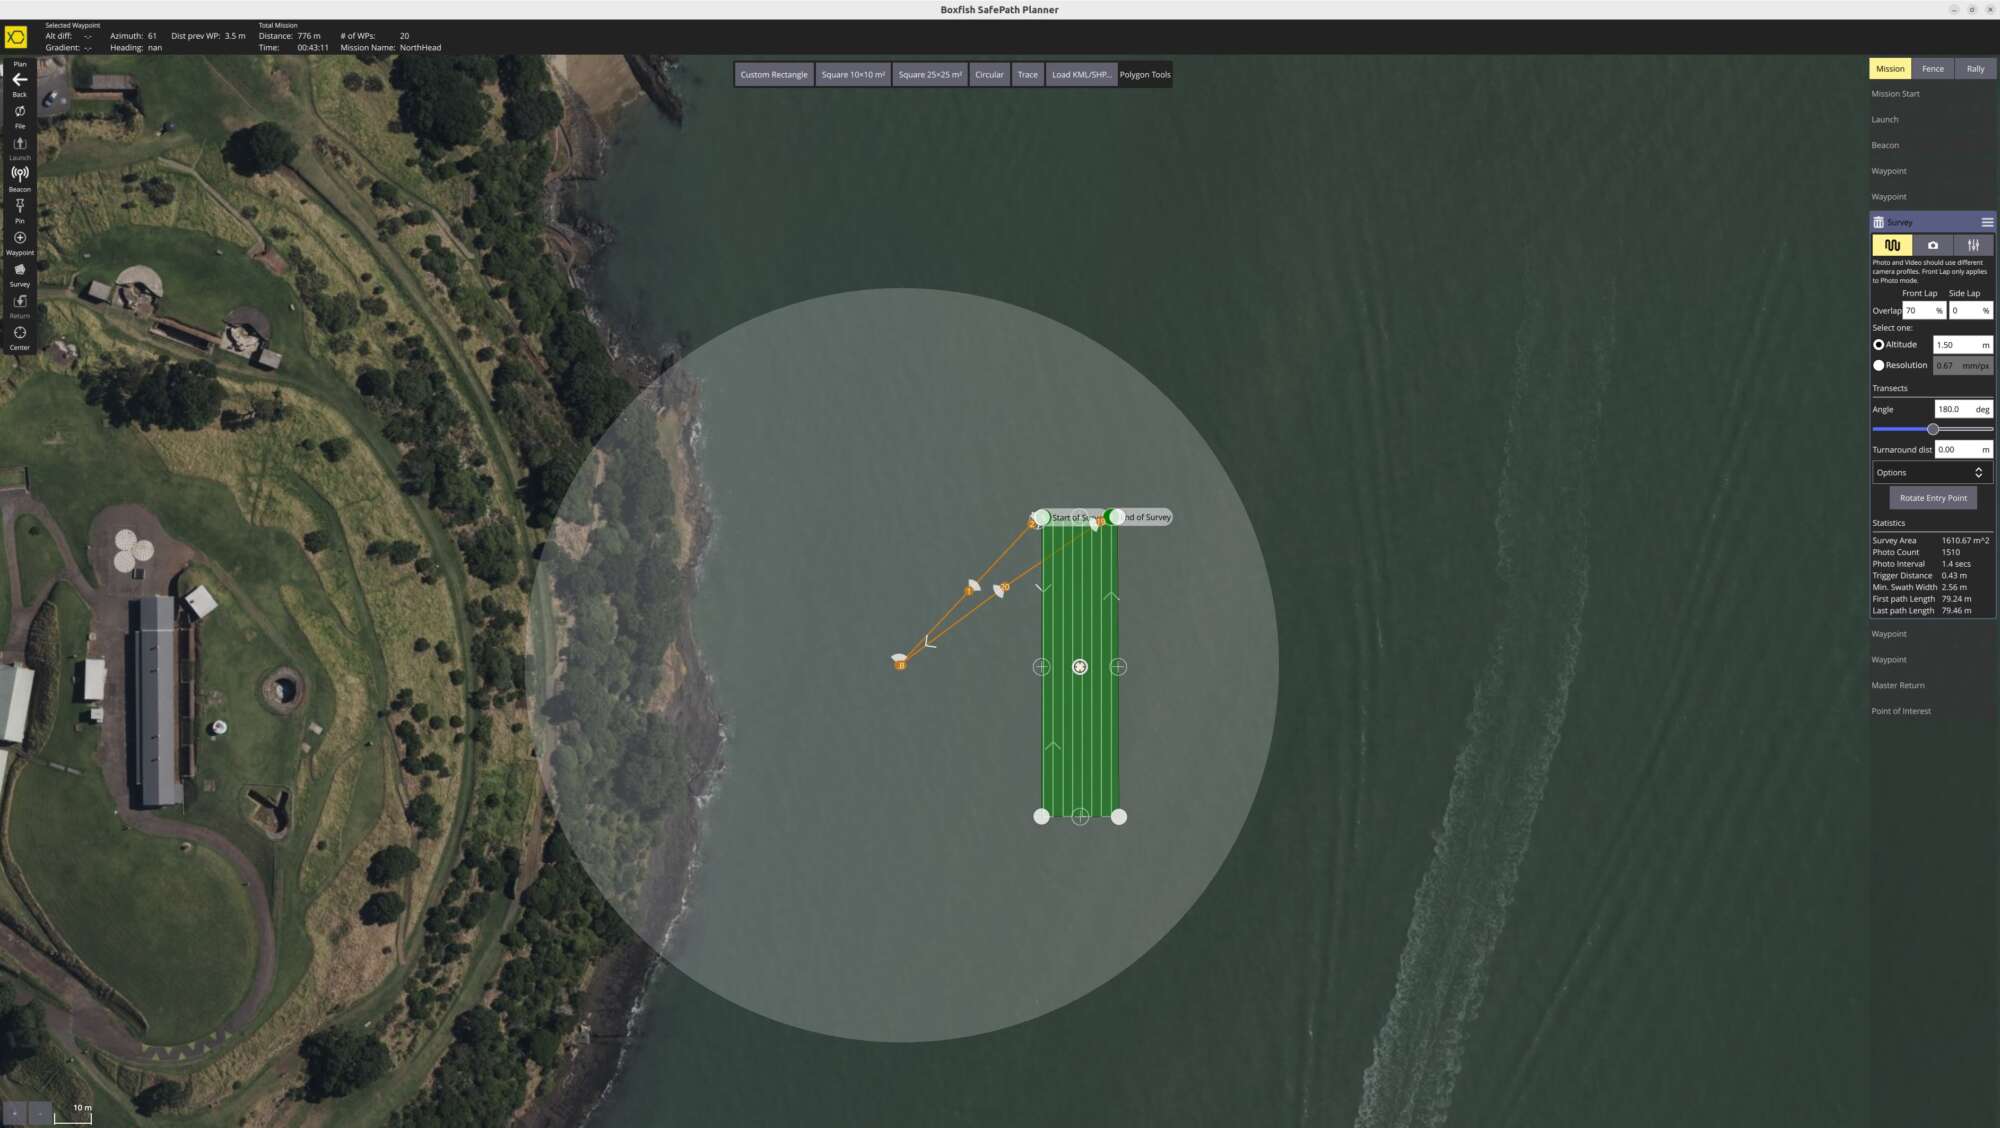
Transect surveys
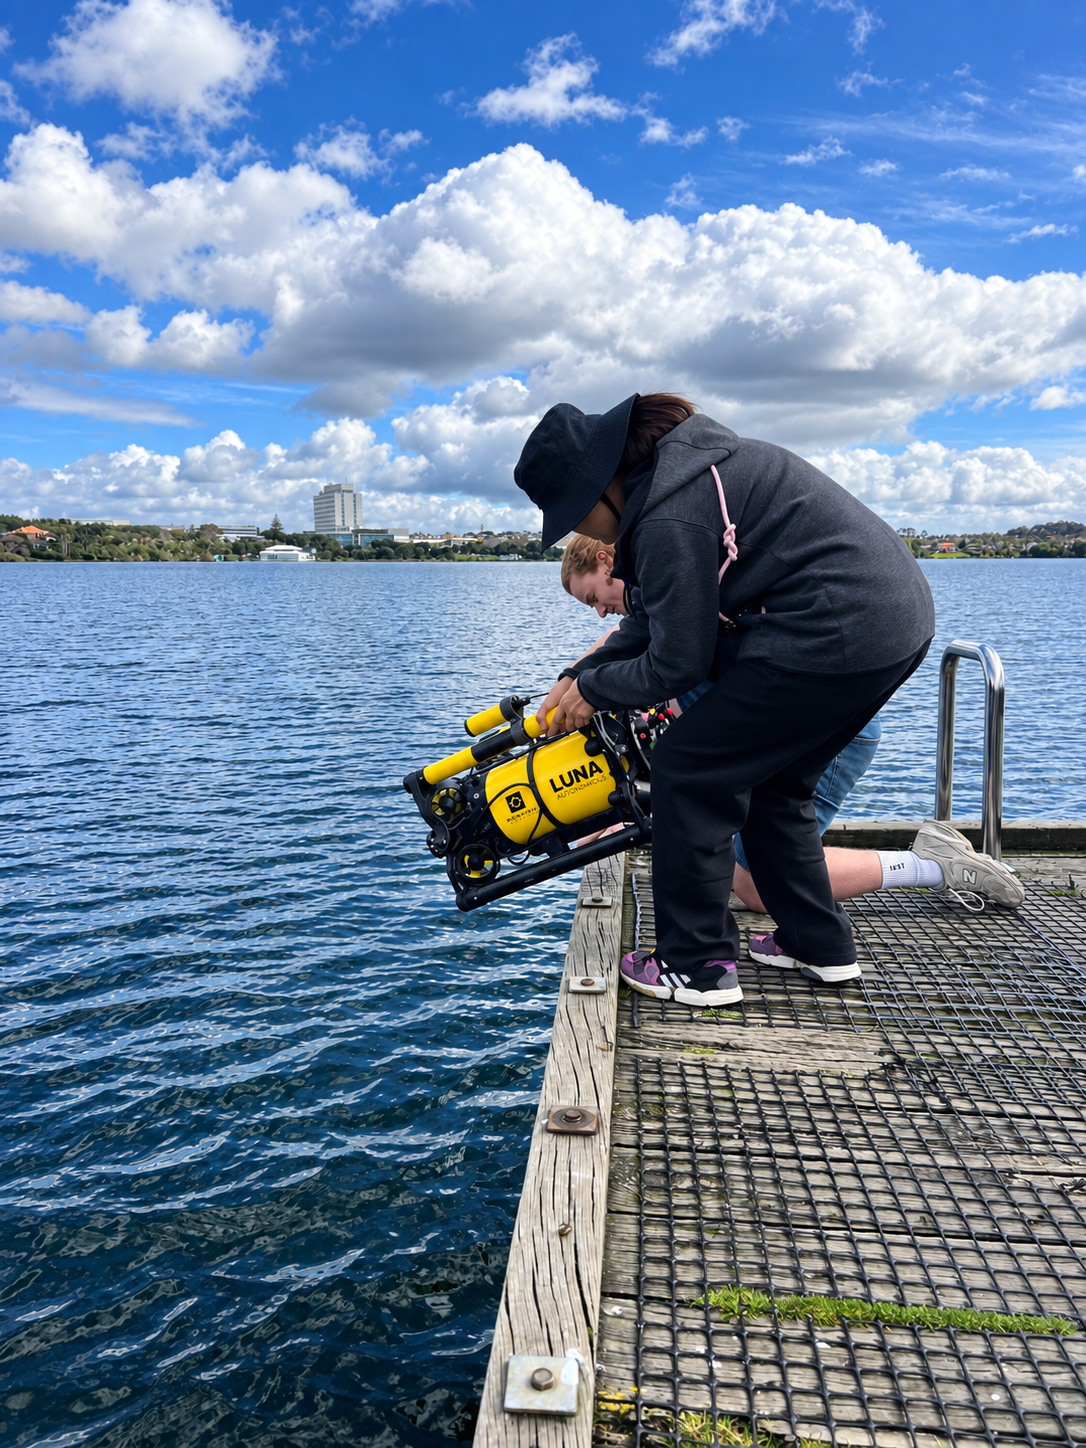
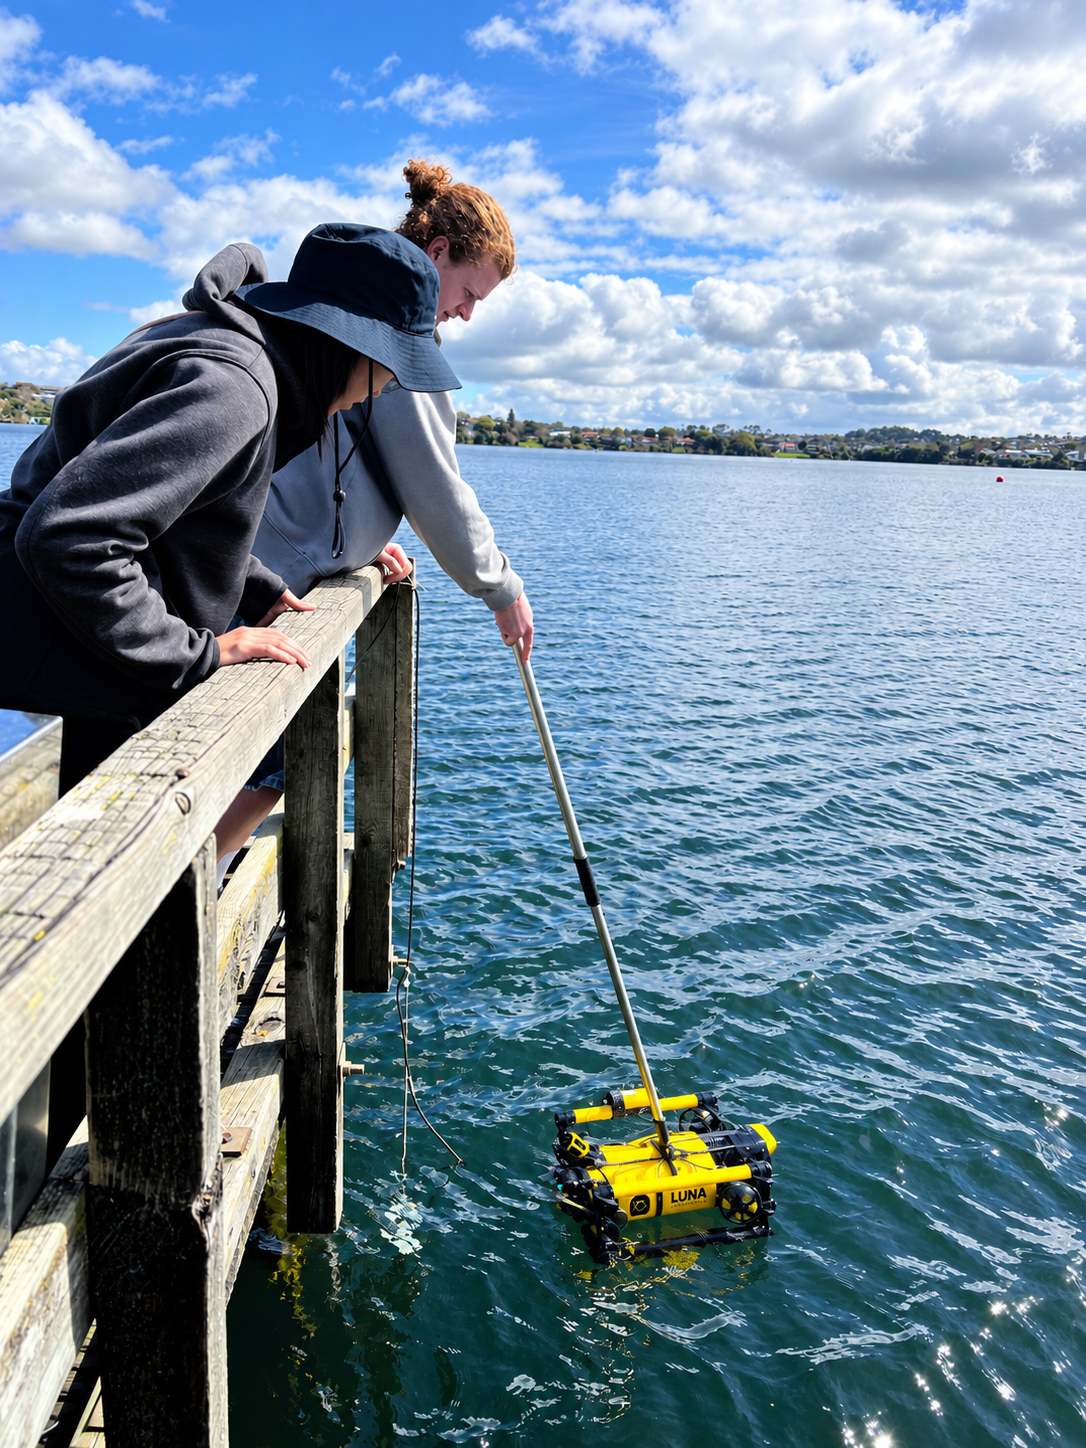
Luna AUV was deployed to conduct autonomous transect surveys across harbour channels and bays. The vehicle collected repeatable geo-referenced imagery along planned survey lines, creating consistent visual datasets across the survey area.
The combination of full-frame imaging, low-altitude operation and precise navigation enables a level of visual detail and consistency that supports mapping, measurement and environmental analysis.
Such surveys provide an efficient method for environmental monitoring, habitat assessment and long-term change detection while reducing the time and cost associated with traditional survey methods.
Contact us to review the survey footage and learn how Luna AUV can support your monitoring programme.
Technical Specifications
General
- Presssure vessel material: Hard anodised aluminium alloy
- Dome Material: Acrylic
- Thruster layout: eight 3D vectored
- Manoeuvrability: 6 Degrees of Freedom
- Fault-tolerant design allows for continued operation even with a failed thruster
- Range up to 6km
- Depth rating: 300m, 500m or 1,000m
- Operating temperature: -10˚C to +45˚C
Camera system
- 4K full frame sensor main camera
Lighting
- Forward: 20,000 lumens, high CRI, dimmable
- Adjustable arms and ball mounts for excellent lighting in all orientations
- Additional forward lighting options available
Physical Specifications
- Dimensions (l/w/h): 730mm / 435mm / 351mm
- Weight (salt water ballast installed): 25kg
Mission Planning Software
- Simple mission generation using grid pattern or simple transects
- Highly customisable interface (pitch, speed, lighting, distance from objects, depth, altitude at any waypoint and multiple USBL beacons)
- Start/Stop image collection, video capture, or sensor data at any waypoint
- Obstacle avoidance and backtracking
Power
- Dive time up to 10 hours (depending on conditions)
- Lithium polymer batteries
- Battery capacity: 600Wh
- Battery recharge time: 5 hrs standard or 45 min fast charge AC/DC field optional
Integrated sensors
-
Depth sensor
-
IMU
-
Internal pressure
-
Temperature and humidity monitoring
-
Battery voltage
-
Leak detection
-
Thruster failure detection
- USBL
- DVL
External connections
- Four Boxfish free standard ports
- Boxfish patented tether connector
- Network: RS232, RS422, RS485 and Ethernet
- Power: 12V @ 50W and 24V @ 50W
Optional add-ons
Stereo camera for fish surveys
Environmental Sensors
- miniCTD
- pH sensor
- turbidity
- chlorophyll
- fluorometer
- hydrophone
Navigation
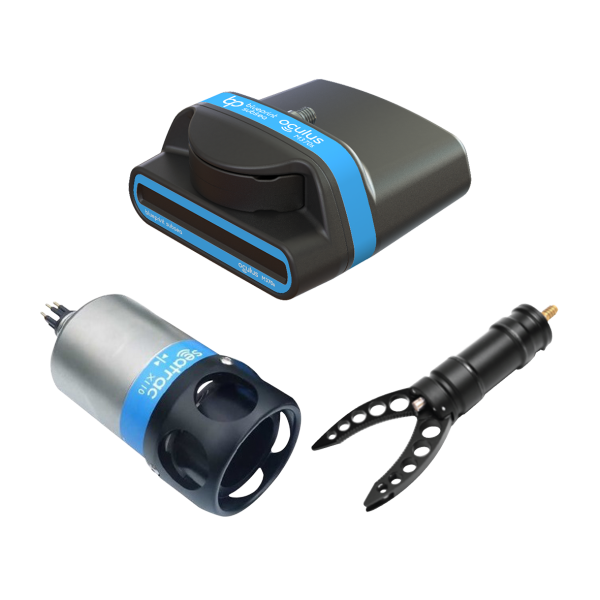
- Oculus Imaging sonar (about multibeam sonar)
Tether & reel (Optional)
- Extremely durable, lightweight fibre optic dia. diameter 2.7mm or 4.3mm
- Tether length as required
- Neutrally buoyant in fresh water
Control station (Optional)
- 17” 4K primary monitor for real-time surface monitoring
- High quality, physical controls for all primary functions
Product Add-ons
Increase capabilities with a range of add-ons and customisations.
Path to Autonomy
Existing Boxfish Luna customers can upgrade their vehicles to Boxfish Luna AUV, providing a practical path from remotely operated to autonomous survey capability while leveraging their Luna platform.
- Build on your existing investment
- Add autonomous survey capability
- Familiar operation and workflow
- Leverage the same imaging platform
The Luna AUV platform also shares common architecture with Boxfish resident systems, providing future pathway to resident docking operation for customers with evolving operational requirements.
Want to learn more about Boxfish Luna AUV?
We can answer any questions you might have. Just fill in the form on our contact page and we’ll get back to you.